
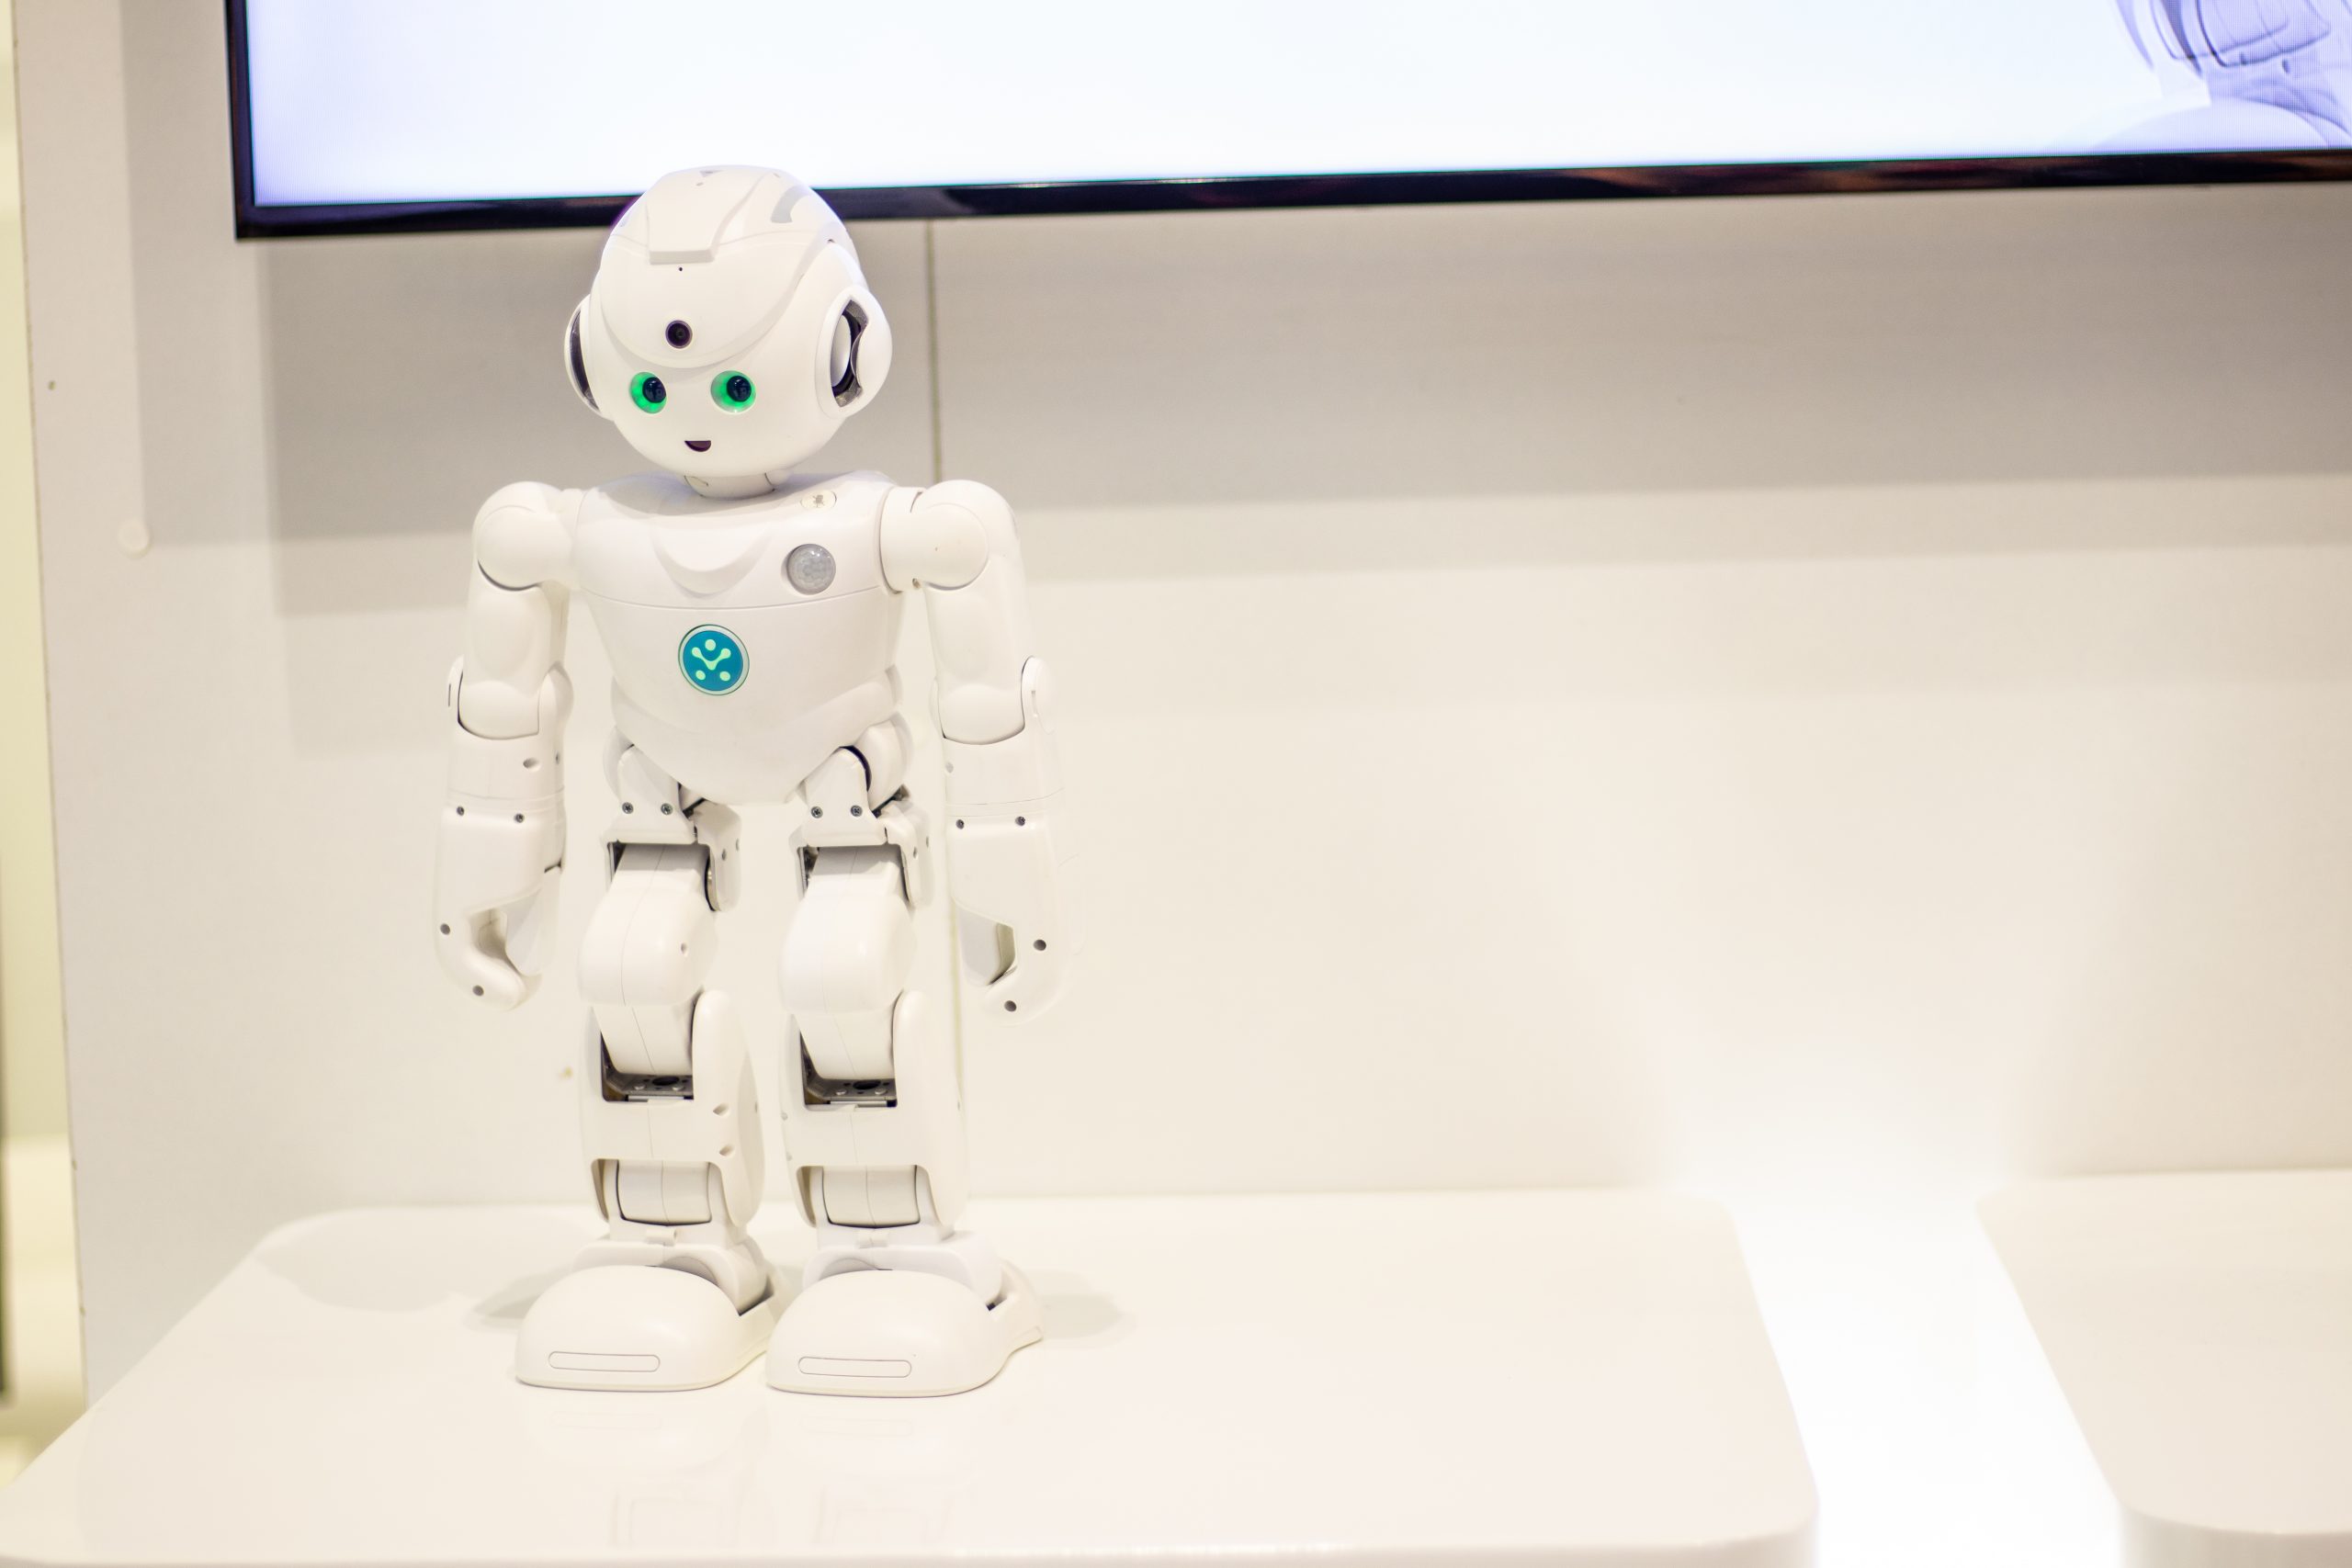
UBTech Unveils Walker C1 Service Humanoid in Beijing: A New Milestone in Robotic Mobility and Design
UBTech has officially introduced its latest service humanoid robot, the Walker C1, at a launch event in Beijing. This new model represents a significant step in the company's humanoid development, featuring a height of 165 cm and a weight of 50 kg. Designed with 26 degrees of freedom, the Walker C1 is engineered for versatile movement and service-oriented tasks. The unveiling highlights UBTech's ongoing commitment to advancing humanoid robotics within the service sector. This article examines the technical specifications provided and discusses the potential impact of the Walker C1 on the broader robotics industry, focusing on its physical dimensions and mechanical flexibility as reported in the initial unveiling.
Key Takeaways
- Official Unveiling: UBTech has launched the Walker C1, a new service humanoid robot, in Beijing.
- Physical Dimensions: The robot stands 165 cm tall and weighs 50 kg, positioning it as a human-sized service solution.
- Mechanical Flexibility: The Walker C1 is equipped with 26 degrees of freedom, allowing for complex and versatile movements.
- Service Orientation: The model is specifically categorized as a service humanoid, intended for interaction and assistance tasks.
In-Depth Analysis
Physical Proportions and Human-Centric Design
The specifications of the Walker C1, as unveiled by UBTech, suggest a design philosophy centered on human-centric interaction. Standing at 165 cm (approximately 5 feet 5 inches), the robot is designed to operate at a height comparable to an average human. This choice in stature is critical for service robots, as it allows for eye-level interaction and the ability to operate in environments designed for human use, such as offices, hospitals, or retail spaces.
Furthermore, the weight of 50 kg (approximately 110 lbs) is a notable technical detail. For a humanoid of this height, a 50 kg weight indicates a focus on lightweight materials and structural efficiency. In the field of robotics, maintaining a lower mass while preserving structural integrity is essential for safety—especially in service roles where the robot interacts closely with people—and for energy efficiency, as a lighter frame requires less power for locomotion and balance.
Mechanical Versatility and Degrees of Freedom
A core technical highlight of the Walker C1 is its 26 degrees of freedom (DOF). In robotics, degrees of freedom refer to the number of independent joints or axes of motion a machine possesses. With 26 DOF, the Walker C1 is capable of a wide range of articulated movements, which likely include complex motions in the arms, legs, and torso.
This level of mechanical flexibility is a prerequisite for a "service humanoid" to perform practical tasks. High DOF allows the robot to navigate uneven terrain, maintain balance while moving, and manipulate objects with precision. By integrating 26 degrees of freedom into a 50 kg frame, UBTech demonstrates a sophisticated level of engineering aimed at balancing mobility with mechanical complexity. This flexibility is what enables the robot to transition from simple locomotion to the more intricate tasks required in a service environment.
Industry Impact
The introduction of the Walker C1 in Beijing marks a significant moment for the service robotics industry. By bringing a human-sized, lightweight humanoid to the market, UBTech is addressing the growing demand for robots that can seamlessly integrate into human workspaces. The specific combination of a 165 cm height and 26 degrees of freedom suggests that the industry is moving toward more agile and adaptable humanoid forms.
As service humanoids become more physically capable, their potential applications expand. The Walker C1's design indicates a shift toward robots that are not just stationary tools but mobile assistants capable of navigating the human world. This launch reinforces the trend of developing humanoids that prioritize safety and versatility, setting a benchmark for what is expected from modern service-oriented robotic platforms.
Frequently Asked Questions
Question: What are the primary physical specifications of the UBTech Walker C1?
The Walker C1 stands 165 cm tall and weighs 50 kg. This human-like scale is designed to facilitate better interaction within human environments while maintaining a lightweight profile for safety and efficiency.
Question: How many degrees of freedom does the Walker C1 have, and why does it matter?
The Walker C1 features 26 degrees of freedom. This is significant because it determines the robot's range of motion and its ability to perform complex tasks. More degrees of freedom generally allow for more natural and versatile movements, which are essential for a robot categorized as a service humanoid.
Question: Where was the Walker C1 officially unveiled?
UBTech officially unveiled the Walker C1 service humanoid in Beijing.


