Building a Robot Pick-and-Place Simulation with SimReady Assets: What the Source Identifies
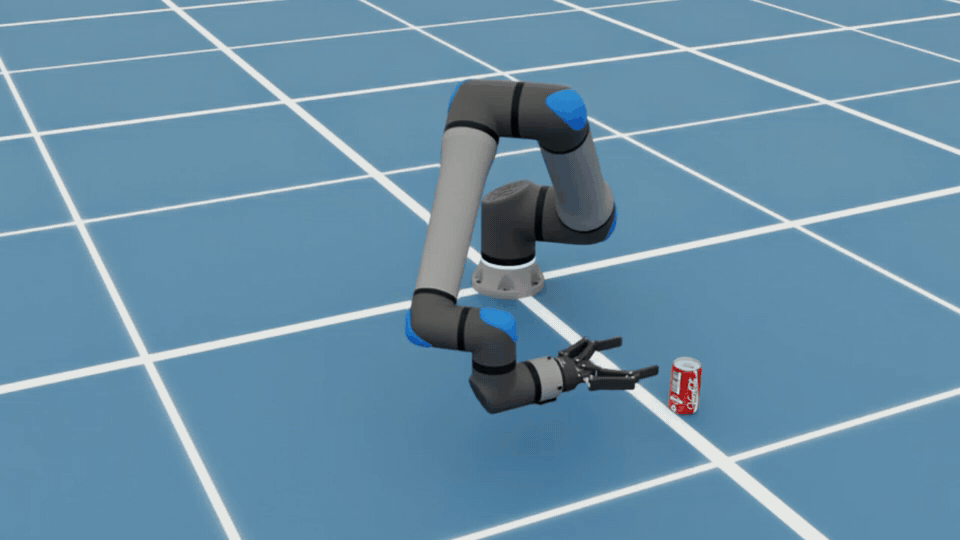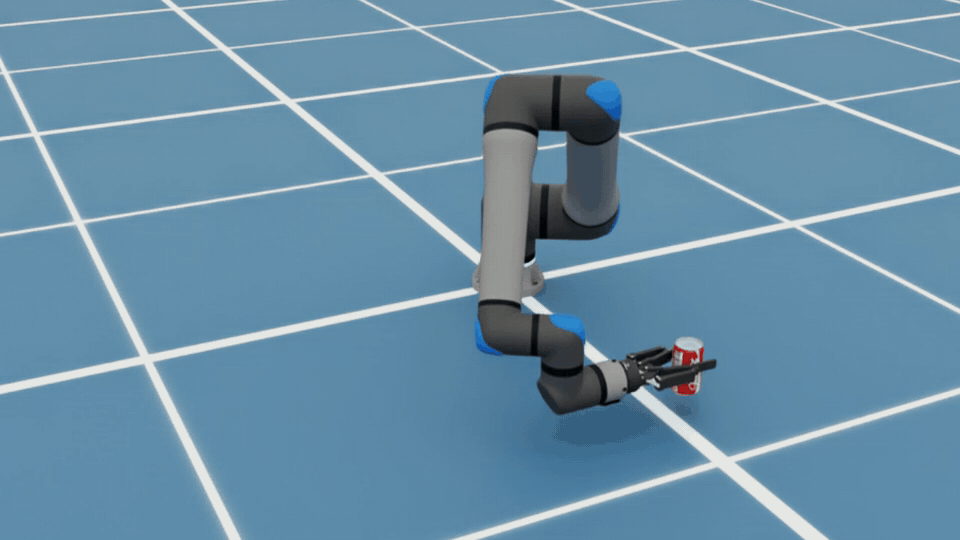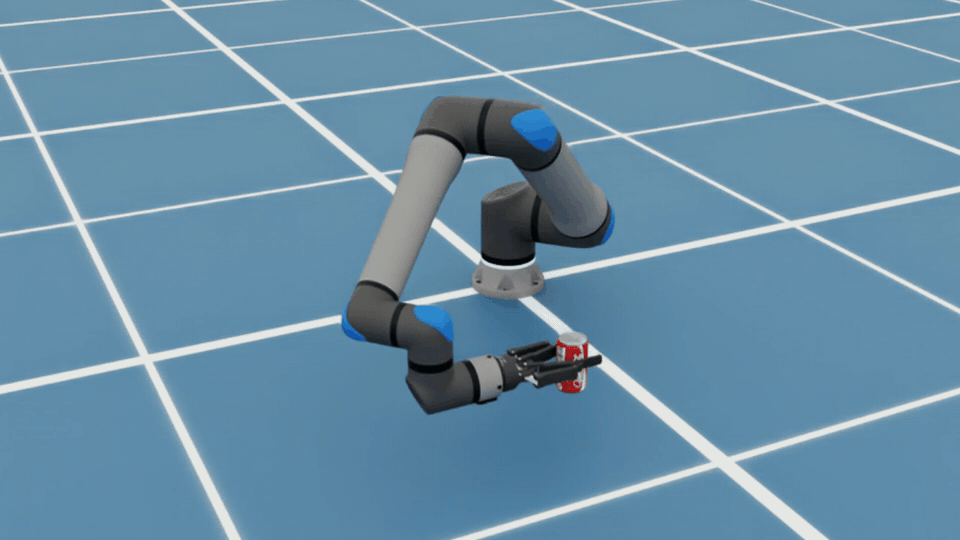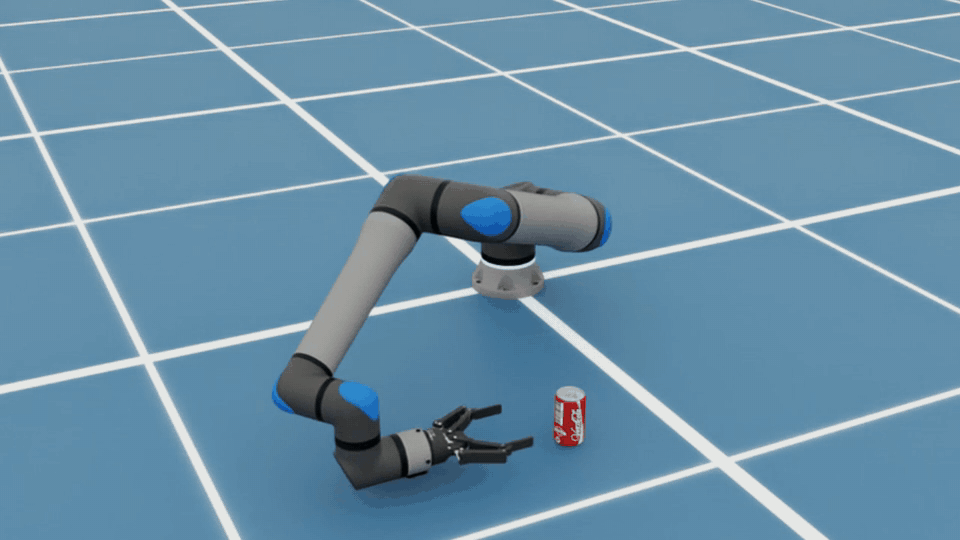
A Hugging Face Blog entry titled “Build a Robot Pick-and-Place Simulation with SimReady Assets” is listed with a publication date of November 13, 2026, at 18:00:39 UTC. The title identifies the subject as building a robot pick-and-place simulation with SimReady assets. The supplied source information includes a link and credits Hugging Face Blog as the author, but it does not include the article body. As a result, the available material establishes the topic but does not identify the robot, specify which assets are used, describe the simulation setup, or report any results. Readers looking for build instructions can consult the linked source; no instructions are included in the supplied material.
Key Takeaways
- The title identifies a robot pick-and-place simulation as the build topic and names SimReady assets as part of it.
- The entry is listed on Hugging Face Blog, with a supplied publication date of November 13, 2026.
- The supplied material contains no article body, so it does not establish a build procedure, technical requirements, or results.
In-Depth Analysis
What the title tells readers
“Build a Robot Pick-and-Place Simulation with SimReady Assets” names both the intended build and the assets associated with it. The word “simulation” is an important qualifier: the title presents a simulation build, not a demonstrated deployment on a physical robot. The wording “with SimReady Assets” links those assets to the build, but it does not say which assets are used or what role any particular asset plays. The title is therefore enough to identify the subject for readers interested in robot pick-and-place simulation, but not enough to explain how the build works.
What the supplied material leaves open
The Hugging Face Blog entry is listed with a publication timestamp of November 13, 2026, at 18:00:39 UTC, and the supplied author credit is Hugging Face Blog. No article body accompanies that information. The word “Build” frames the topic as a practical task, but the headline alone cannot establish whether the full post includes a walkthrough, code, or asset references. It also does not name a simulator, identify a robot model, or describe how the pick-and-place task is set up. Those are limits of the supplied material, not claims about what the linked page contains.
Industry Impact
The available information identifies a topic at the intersection of robotics simulation and SimReady assets, but it does not support a conclusion about the build’s impact on the AI industry. There are no supplied results or comparisons that would show whether this approach changes setup effort, improves simulation performance, or affects how a workflow transfers to physical hardware. Likewise, the title does not establish that the build involves training or evaluating an AI model. The distinction matters for readers assessing the entry: a stated build topic is not evidence of a technical improvement or a deployment outcome.
Frequently Asked Questions
What is the Hugging Face Blog entry about?
Its title identifies the topic as building a robot pick-and-place simulation with SimReady assets. The entry is listed with a publication date of November 13, 2026.
Does the supplied material include instructions for building the simulation?
No. It provides the title, source link, author credit, and publication timestamp, but no article body. Whether the linked post includes instructions or code cannot be determined from the supplied material.
Which robot and SimReady assets does the build use?
The title names SimReady assets collectively but does not identify individual assets or a robot model.